Saturday, December 15, 2012

New Sack Attack Robots

Over the past weeks we have done a lot of work on our robots.  After winning 2 consecutive competitions we found that our designs worked very well but may have needed some tweaking.

Spatula Bot 

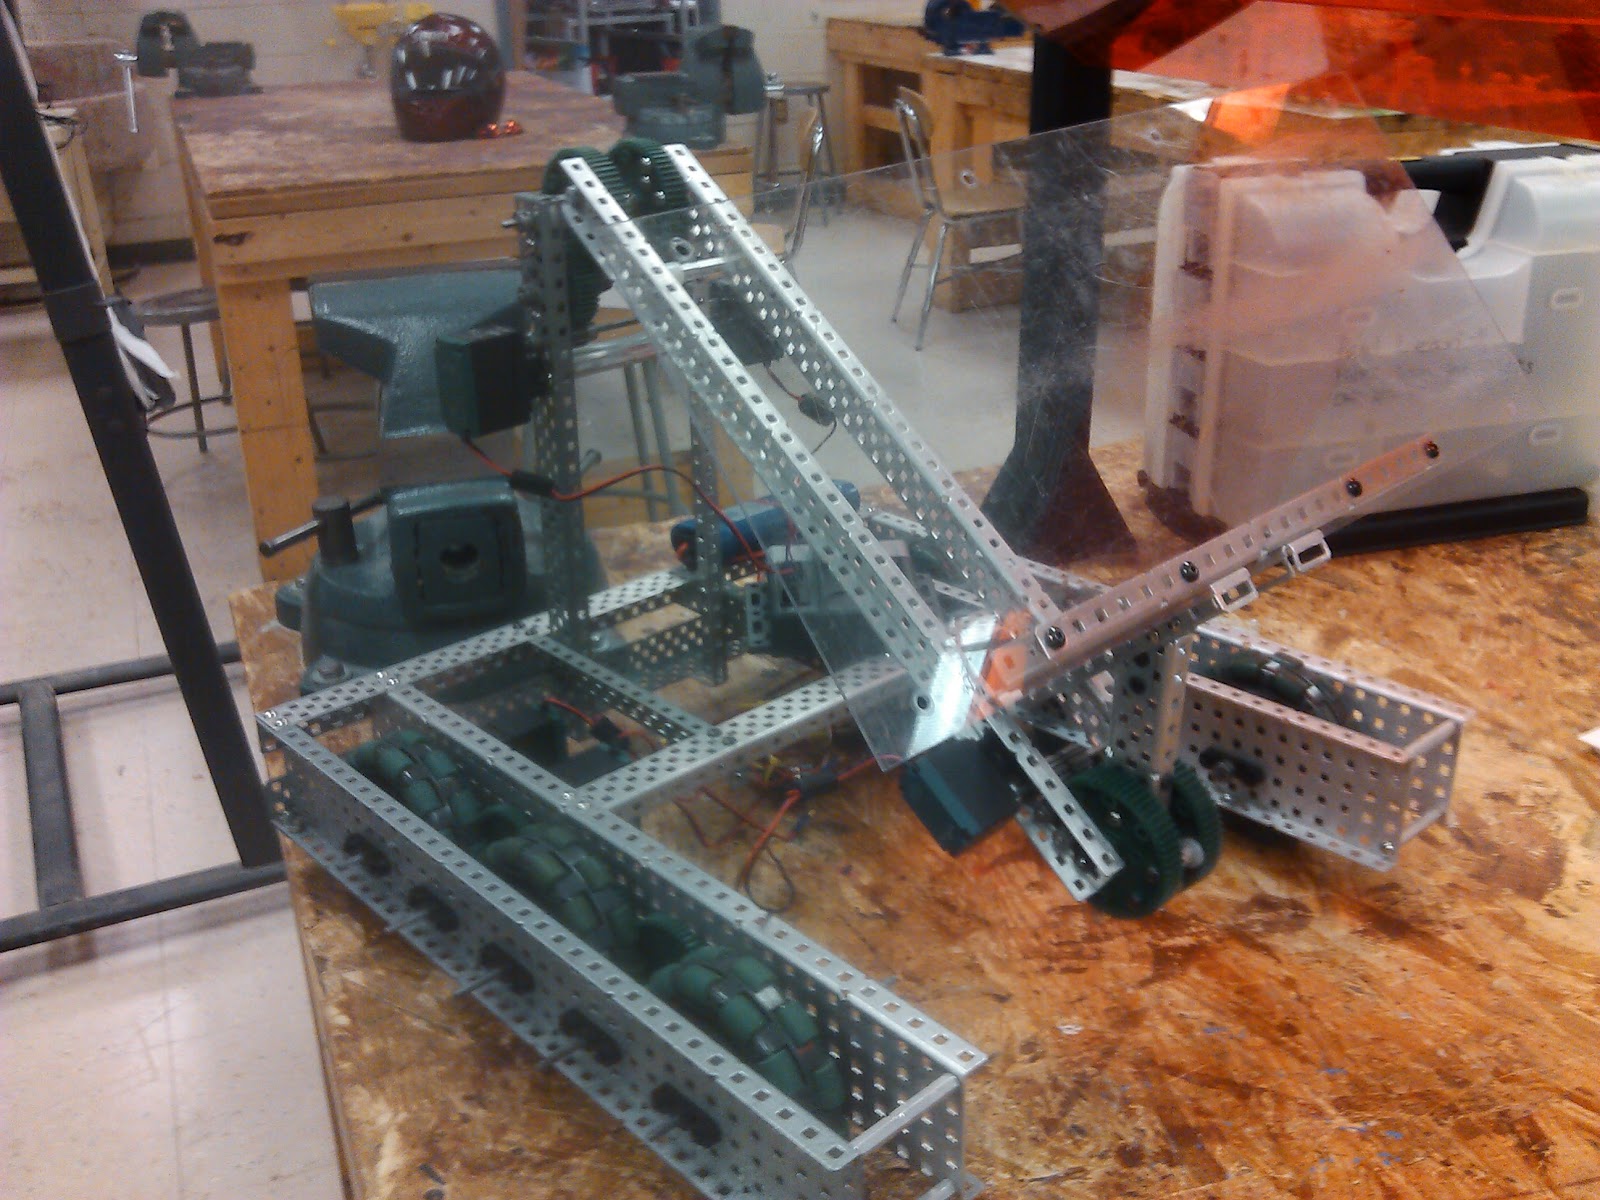
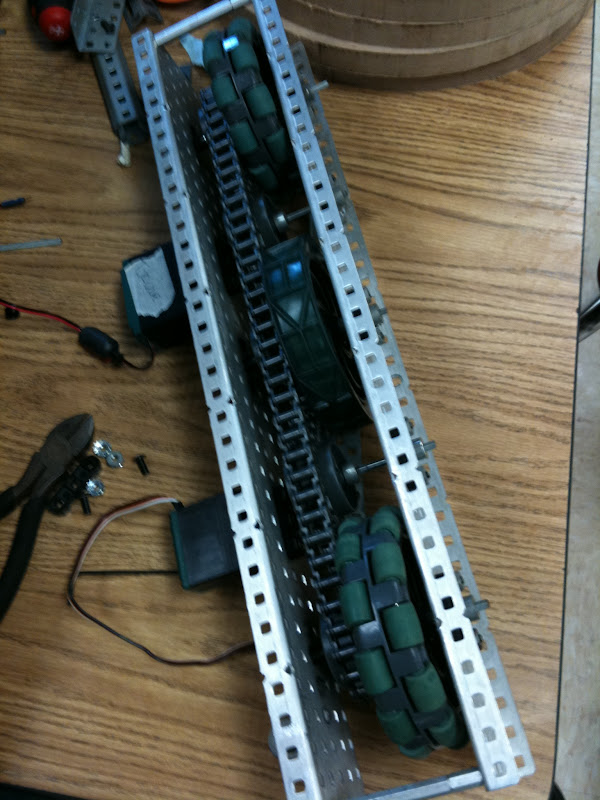
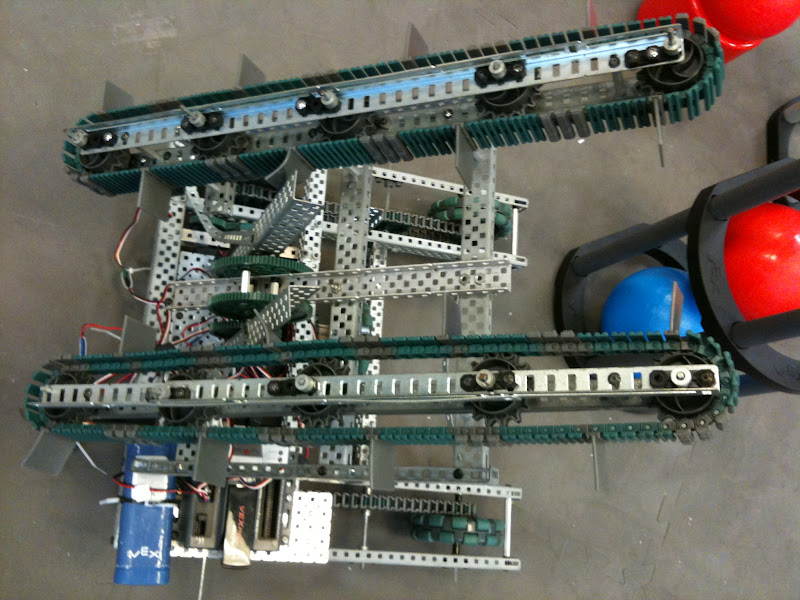
After winning the Dover Air Force base regional we found the over the back scoring method to be very effective and simple.  However we decided that we wanted to carry many more game pieces.  After watching some of the New Zealand world championships we knew exactly how we wanted to do it.  We recently made a flipper to intake the sacks into our original spatula.
We tested the robot today and it was able to score 15 sacks at once without any surgical assist.
Tuesday night we plan on completely re-wiring the robot and changing some code.

Shelf Bot

Our shelf bot won the Delaware County Christian School scrimmage after getting shut down by our spatula bot at Dover.  They took advantage of a win and the new experience with their scissor lift to improve it greatly.
video here http://www.facebook.com/photo.php?v=10102003960399228

Freshman Bot

Our freshman made successful robot placing in the semi-finals at the Delaware County Christian School scrimmage.  They have been using a chain bar arm with a leg wheel intake.  Their best strategy was the successful "gold sack strategy" where they got the gold sacks all over the field as fast as they could and scored them.

There will be new posts more frequently now that we have more changes going on.


Tuesday, October 2, 2012

Sack Attack Autonomous

New 357 Autonomous

We now have a successful autonomous.  Our simple mechanism is able to score 3 to 4 sacks in autonomous and has a very successful driver control period.  We will be attending the Dover Air Force Base competition and we are coming to compete! We have come to a complete design and are very happy. We will be a strong competitor at the event.

Saturday, September 22, 2012

Meeting of 9-22-2012

Scissor
We are nearing the Dover Air Force base competition, so everything Vex is in overdrive. The scissor lift bot is up and running. We routed all of the PWM cable through the frame, adjusted the code to accommodate the physical changes. A drastic change done to the bot in the past couple of weeks was the spatula has been upgraded to have an active intake. After a few trial runs, we found that the intake was not intaking as much as we would have hoped. To fix this, we began work on way to allow for the intake to adjust its height to allow more sacks.
Things to note / updates quick list
  • active intake
  • side walls
  • new spatula arm
  • thinner tray w/o spaces
  • smaller frame
Things to be done before competition
  • add a back wall
  • finish intake
  • finish engineering notebook
Spatula
The main thing being done is coding. Only small physical changes have occurred. 

Thursday, August 16, 2012

Meeting of 8-16

Scissor Lift Bot:
Tonight, we mainly focused on getting the spatula to pick up and deliver sacks to the tray.
So far, the spatula has no problem picking up the sacks, but, the delivery is somewhat of an issue. It will be resolved the next time we get a chance to work on it. (Most likely not this Saturday)


The spatula is being powered by a 1:5 ratio using 2 269 motors. 
For the next meeting, we plan on trimming the top of the spatula arm and adding something in the front of the base to prevent sacks from entering the base.

Spatula Bot:
The robot itself did not receive much mechanical work. The main focus was on programming autonomous. The students working on this bot also added a limit switch that will trigger when it reaches the underside of the trough. Unfortunately, there were no videos taken.

Saturday, August 11, 2012

Meeting of 8-11

Today, my mentor, Ryan, and I worked on a scissor lift concept.
Each side of the lift is powered by a high strength 2-wire motor. The motor drives a 12-tooth gear into a stationary 60-tooth gear.
Atop the lift is a tray comprised of tread. This tray will have sacks put onto it by a spatula.


After we finished building the lift, we tested to see how many sacks it could handle lifting:
(5 sacks)
(10 sacks)
`(15 sacks)
(20 sacks)

Please note that this is just a build concept, not the final design. There is still much mechanical work to be done so stay posted.

Thursday, July 12, 2012

Spatula Bot


We have created a new mecanum drive with our new spatula mechanism.

This robot is now performing quite well even at its early stages.
Note that this is not a complete robot and will still be subject to change.
Also we are trying some "unique" ways to fit into the 18*18*18 in box

 also note that there were some "operator errors" during this video


Friday, June 15, 2012

New Mechanisms

Mechanisms

We have been trying out some spatula design intakes.
Here are some cool pics of our design.


The Mechanism is composed of a polycarb plate to slide under and lift sacks.
After testing we have found the spatula to be very successful on its own but the tower is not fully complete for testing.


Tuesday, June 5, 2012

06/02/12 Intake Mechanism Tests

Stand off mechanism

We have been working on a mechanism which uses stand off intake rollers to catch the sacks easier.
We tried the mechanism in several different ways.

Intake at different angles:


We found that while flat on the ground the sacks got stuck on the intake. 
However when we put the intake at an angle it had a much easier time with the sacks.

Intake multiple sacks:


Although this video was not very accurate, we found that the intake was able to successfully intake multiple sacks.

Intake attached to Vexter drive:


In order to fully test the mechanism we attached it to our mecanum drive.
Overall the mechanism was successful and will be further tested.

Friday, May 11, 2012

05/10/12 - Scoring / De-Scoring Prototypes

The team talked about various scoring and de-scoring strategies last night and began prototyping an intake that can both pick up sacks from the floor and de-score or steal sacks from the trough goals. Below are our test videos, all tests were ran with two 269 motors direct driving the wheels:

Test 1: Using a 5 inch wheel for de-scoring from the trough goals.


Result: 5 inch wheel does not grip the sacks well and does not de-score them easily from the trough.

Test 2: Using the 30 tooth sprocket with small tread flaps wrapped around the outside.


Result: Small flaps worked better than the 5 inch wheel and could de-score some sacks. Decided to try larger flaps to see if that worked better.

Test 3: Using the 30 tooth sprocket with some small and some large flaps wrapped around the outside.


Result: De-scored fairly well. We are going to experiment with using a piece of extendable polycarbonate to support underneath the sacks for sack stealing purposes.

05/05/12 - New 6 Wheel West Coast Drive

We have created a 'West Coast' style drive using 5 inch wheels that are cantilevered on the outside of the frame. The drive uses four 393 motors geared for torque. The overall gear ratio uses 60:84 tooth gears for a 1.4 ratio to increase our speed. See the images and video below -


Thursday, May 3, 2012

Week one Sack Attack

2012-2013 VEX Sack Attack

Initial tests and notes:
            Current "Vexter Drive":  Mecanum drive 1:1.6 ratio, HS motors set to speed setting.
            Back drive pods are on a joint for movement over obstacles
            Current "Vexter Drive" height:  0.8 in
            Spacing between the front and back pods:  3.3 in

            Sack Specs:
                     Sack not fully flattened: about 2 in
                     Sack on Side:  about 3 in

Tests

                                     Driving over one sack:


                                  Overall success, sack caught on back drive pod.

                                  Trying to push 5 sacks:


                                   Result: Failure 2.5 lbs of sacks cannot be pushed by this drive (yet)

                                 Trying to Drive over 5 sacks:

                        
                                  Overall success, able to move around sacks it was stuck on.

Final Thoughts

Drive has great maneuverability
Able to drive over some sacks 
Able to translate over sacks in the center of drive
Unable to push more than 2 sacks
May need to lower wheels in drive pods to increase clearance
Sacks are definitely a field obstacle

Wednesday, February 29, 2012

Friday, September 30, 2011

Update from 9-29


Recently, we noticed that the arms on my robot wobbled too much. So we set out to fix this. What we came up with was surgical tubing going from connection point of the two arms to a rail. As the arm moves to different positions, the support will move along the rail to line up and continue to provide support.

Sunday, September 18, 2011

Grand Ol' Update

(1)(2)
(3)
(4)
(5)

Many advancements have been made on the 6WD robot. The roller claw has been finished and added to the robot. On the 2nd stage of the arm, we've added a 5:1 gearing from the motor to the sprocket. This will make it so that the arm can support the weight of the claw and game objects. (picture 1-3)

The other team has also finished their intake system. They added gearing on the top of the tower so that it can pivot to reach higher towers. Testing for this mechanism will be most likely be done Saturay the 24th. (pictures 4-5)

There will be no updates on Tuesday the 20th or Thursday the 22nd.

Friday, September 2, 2011

Update from 9/1

In preparation for upcoming events. We've decided to create a sensor bot. Using the values/codefrom this bot, we will create autonomous codes for our competition bots.


For my robot, I've added the second stage of the arm. During our next meeting, I will prototype a roller claw.


There will be no update for 9/3 due it beeing Labor Day weekend.

Thursday, August 25, 2011

Last Week Off Before School Starts

The area where we usually meet is being cleaned heavily this entire week and upcoming weekend, so the entire team is taking a week off before school starts next week.

We are going to start recruiting for the incoming freshmen and it will be interesting to see how we handle this Fall semester. Last year, the new students worked alongside the veteran members. This year, we may try and field a truly freshmen team and a sophomore fall semester team.

Below is the latest update from the robot that our student Evan is working on -


Below is potentially one idea for what will become the second stage of this arm -


Thursday, August 11, 2011

Update from 8-11

Here's a quick update from earlier tonight. We weren't able to do much tonight because we were preparing for Saturday's FRC competition.

The H-Drive had some tower updates. Rack and pinions were added to the tower so that the mechanism can reach the 30" goals. The picture shows one side of the tower, the other side was added after the picture.
The 'H' in the drive was removed so that the tower/mechanism could use more motors

For the 6-wheel drive, I started prototyping a 6-bar linkage/extended 4-bar.
Next Tuesday, I will upload pictures of the prototype. (no Saturday update)

Update from 8-9 Meeting


The above photos are of the completed 6-wheel drive train that I've been working on. I plan on adding gripping on the middle traction wheel so that they are level with the omni-wheels.
Before I add the tower+claw from the other drive, I plan on prototyping a 6 bar linkage and a roller claw. (not necessarily together)

Another member of the team has been working on a drive to support his mechanism. (the c-shaped drive in the video below) The drive was made from a failed holonomic base that was attempted beforehand.
Disclaimer: this base is not to be confused with the other C-Drive/Bracket Drive that I've made.


Our h-drive has also been tested recently.
The video (below) show how the mechanism works. The other members plan on adding support to the mechanism to prevent the shaky behavior when moving. Linear actuators will also be added so that the mechanism can reach the 30" goals.


Sunday, August 7, 2011

Update from 8/6 Meeting

This past Saturday, many changes were made to my robot. I've completely redone the drive from the ground up. The bracket drive was not working out due to tipping and excessive weight. This lead to a new 6-wheel drive train in its place.


The drive uses 4 motors to power chain connected to 6 wheels.

The other robot our team is working on has been upgraded in terms of a mechanism.


The mechanism intakes from the front of the drive, then rotates upwards and reverses the intakes so that objects fall into the goals.

Monday, July 11, 2011

07-09-11 Weekend Update

Just a few more photos from the weekend, the 4-bar is coming along nicely, still trying to figure out a way to integrate extending linear slides to connect to the claw -


And here's the table of concepts and drives so far. Getting to the point of just integrating everything together -


Lots of tweaks and changes still happening though. Most likely these robots will still look different in the coming weeks ahead. Don't expect much of an update this week, the students are helping run a VEX summer camp for incoming freshmen students. This will serve as a fun summer learning experience for the incoming students, and possibly a way to drum up interest for the team once the school year starts.